How Does It Work?
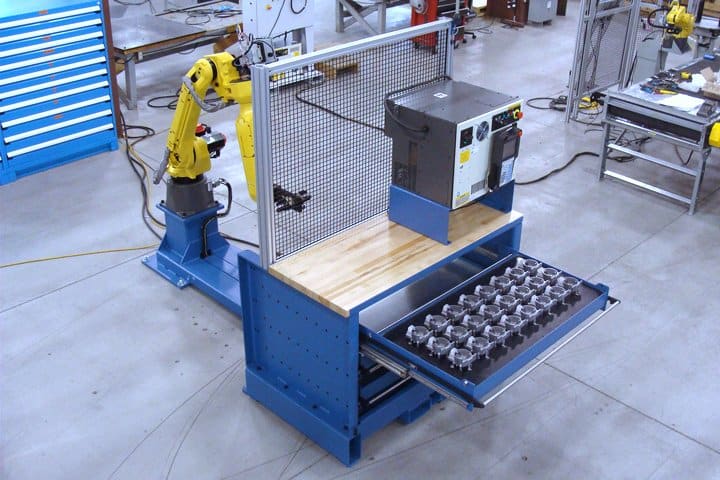
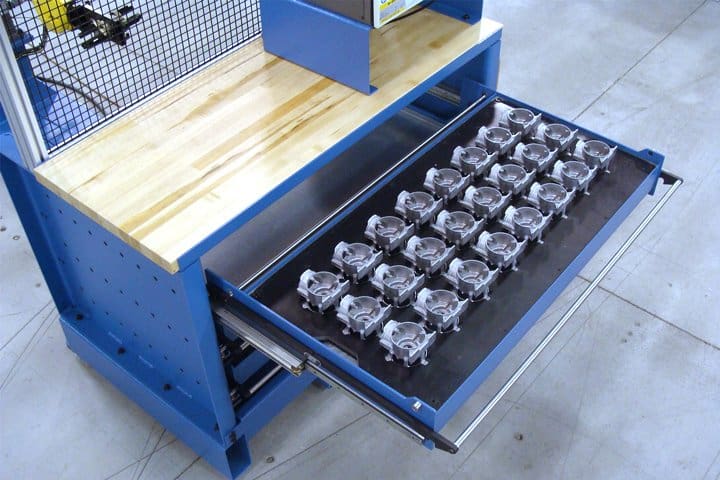
An operator simply opens each of the drawers from outside the robot cell, places raw parts into each drawer fixture and then closes each drawer. Next, the operator cycle starts both the machine tool and the robot. The robot moves to the top drawer, lifts the drawer handle, pulls the drawer into the robot cell and locks it into position for part unloading.
The robot now unhooks from the drawer handle, picks the first part from the drawer and then loads the machine tool. On the next cycle, a finished part is unloaded from the machine tool and a new raw part is loaded. The robot moves back to the drawer to place the finished part back into the drawer. As drawers are completed, the robot moves down to the next available drawer.
Benefits
Operator can access drawers not in use by robot and refill with raw parts
Uses customer-made fixture plates reducing cost
Provides good line of sight to machining process
Tabletop provides convenient place for part inspection after processing
Integral fork pockets provide easy relocation of drawer cabinet
Quick installation and commissioning of system
Features
Compact size
48” W x 24” D x 6” H fixture area (5” H on 4 Drawer units)
Integrated fork pockets
250 lb capacity per drawer (parts and fixture plate)
Integrated galvanized drip tray
3-position drawer locking (robot, mid and operator)
Drawer position sensors are collected and tied into an ethernet IP distribution block
3 or 4 drawer units available
Options
Fully integrated system with robot, EOAT, and safety fencing
Any other peripheral equipment for system
FANUC training and startup assistance
Ethernet connection for remote factory support
Our Most Recent Success Story
Let’s Connect
Get in touch for an introductory call with our team.
Fill out the form or call (800) 724-5794